
#Building a 3d printer because parents won't let my get another off the shelf one
1 messages · Page 1 of 1 (latest)
 sharp musk
 naive elbow
I like the title
 spare needle
malicious compliance 😄
 mellow lodge
Those profiles looks massive
sharp musk
mellow lodge
Those profiles looks massive
4040
 fallen nymph
sharp musk
Also the whole printer will be modular so i can choose what part to build
These are Nema 23s? The mounts will flex from the tension and drive force, shafts won't be happy either
sharp musk
fallen nymph
These are Nema 23s? The mounts will flex from the tension and drive force, shaft...
ok? what are some suggested solutions
fallen nymph
sharp musk
ok? what are some suggested solutions
Make stepper mounts stiffer, check if you can stay within max radial load rating of the stepper or if you need to go for double shear
sharp musk
fallen nymph
Make stepper mounts stiffer, check if you can stay within max radial load rating...
thicker motor mounts?
fallen nymph
sharp musk
thicker motor mounts?
Add trusses etc
sharp musk
fallen nymph
Add trusses etc
example?
fallen nymph
sharp musk
example?
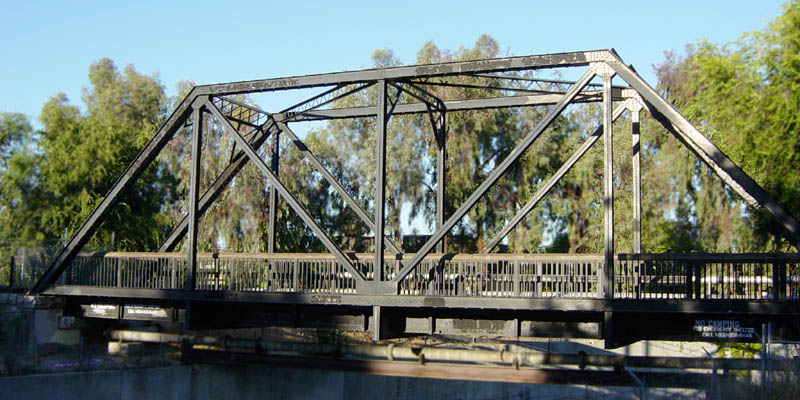
A truss is an assembly of members such as beams, connected by nodes, that creates a rigid structure.In engineering, a truss is a structure that "consists of two-force members only, where the members are organized so that the assemblage as a whole behaves as a single object". A "two-force member" is a structural component where force is applied ...
sharp musk
fallen nymph
https://en.m.wikipedia.org/wiki/Truss
hmm, i feel like theres some potential in this idea
fallen nymph
sharp musk
hmm, i feel like theres some potential in this idea
Yes, that's why you see trusses everywhere, because they work and they're great
sharp musk
fallen nymph
Yes, that's why you see trusses everywhere, because they work and they're great
ok
sharp musk
fallen nymph
Yes, that's why you see trusses everywhere, because they work and they're great

good?
 sharp musk
fallen nymph
trussed

 sharp musk
fallen nymph
im designing a plate like thing to connect both the top and bottom mounts from the right
sharp musk
fallen nymph
 fallen nymph
sharp musk
You want it to work in shear
sharp musk
fallen nymph
You want it to work in shear
what that mean?
sharp musk
Bed tilt leveling and maybe multi axis printing? idk will this work
 fallen nymph
sharp musk
what that mean?
Plate won't be stiff in this direction
spare needle
sharp musk
Bed tilt leveling and maybe multi axis printing? idk will this work
Look up maxwell kinematic mounting, far easier
fallen nymph
spare needle
Look up maxwell kinematic mounting, far easier
Especially considering that this one is overconstrained as
w = 7 × 6 - 9 × 5 = -3 (it's removing 3 degrees of freedom more than it should)
spare needle
no idea what you just calculated so I'm taking your word for it 😄 I just looked at it and my brain said " Nah, doesn't look right. Hows that supposed to be moving? Tilt "
fallen nymph
spare needle
no idea what you just calculated so I'm taking your word for it 😄 I just looked...
w is mobility
Every moving assembly gets 6 degrees of freedom at the start, hence 7 × 6 (2 pieces for each arm and the bed, gives 7 total)
From this we subtract the amount of degrees of freedom each joint takes. There are 6 linear rails that remove 5 DoFs each and 3 simple rotational joints removing 5 DoFs total
Both of these give 9 × 5
So we're starting with 42 DoFs and we're removing 45 DoFs
sharp musk
im a kid with a printer and i don't understand this stuff. please elaborate
spare needle
fallen nymph
`w` is mobility
Every moving assembly gets 6 degrees of freedom at the start, he...
Thank you. I have to say, I love reading your replies in general. Learning every time 😄
sharp musk
spare needle
Thank you. I have to say, I love reading your replies in general. Learning every...
um... what does this mean
spare needle
sharp musk
im a kid with a printer and i don't understand this stuff. please elaborate
was a reply to Deddy
sharp musk
fallen nymph
Plate won't be stiff in this direction
i just copied the stuff off hevort printer cad
sharp musk
spare needle
was a reply to Deddy
i just need tips on how to improve lol
fallen nymph
sharp musk
i just copied the stuff off hevort printer cad
Hevort uses spherical bearings
spare needle
sharp musk
i just copied the stuff off hevort printer cad
they use these short rail segments instead of a steelball and 2x2 cm of steel rod
?
fallen nymph
spare needle
they use these short rail segments instead of a steelball and 2x2 cm of steel ro...
Yep
Hevort Z assembly
 spare needle
to my untrained eye this seems overly complicated......they probably have a good reason for it
sharp musk
fallen nymph
Yep
yeah thats what i tried to copy
i just used a ball bearing because i don't know what the weird screw thingy is
 fallen nymph
sharp musk
i just used a ball bearing because i don't know what the weird screw thingy is
Rod end spherical bearings
fallen nymph
spare needle
Thank you. I have to say, I love reading your replies in general. Learning every...
Now replace simple rotational joints (which remove 5 DoFs) with spherical joints (which remove 3 DoFs) and recalculate 
sharp musk
fallen nymph
Rod end spherical bearings
they look like this? are there standard part numbers or something?
 fallen nymph
sharp musk
they look like this? are there standard part numbers or something?
Yes to both
sharp musk
fallen nymph
Yes to both
nice, but i think il probably use the thing i designed for now because i don't have the patience to wait for hardware to arive
 grave coral
sharp musk
nice, but i think il probably use the thing i designed for now because i don't h...
It wont work
The issue is that if the bed tilts you only have forwards backwards rotation in the bed mounting so at a minimum 2 of the mounts are going to be twisting in an axis they dont like
You need the spherical bearings for the design you have
Oop somewhat late reply, didnt notice the dates
spare needle
Still relevant
fallen nymph
grave coral
The issue is that if the bed tilts you only have forwards backwards rotation in ...
Yep, missing 6 DoFs freed to run triple Z
fallen nymph
grave coral
also is there any benefit to gearboxed nema 23s on this
N32s don't seem gearboxed
 fallen nymph
grave coral
what's this thing then?
Probably couplers to get 5 mm shafts since N23s tend to have 8 mm
grave coral
I just assumed it was a small reducer or something
grave coral
fallen nymph
Probably couplers to get 5 mm shafts since N23s tend to have 8 mm
ah that would make sense
I feel like it would be easier to just bore out pulleys though
fairly easy on a drill press
sharp musk
grave coral
fairly easy on a drill press
i don't have drill press,
sharp musk
grave coral
is that not a gearbox?
no
sharp musk
grave coral
ah that would make sense
yeah
fallen nymph
sharp musk
yeah
Remember that it causes high radial load
sharp musk
fallen nymph
Remember that it causes high radial load
i don't understand this stuff elaborate.
fallen nymph
sharp musk
i don't understand this stuff elaborate.
Belts will be pulling on these shafts in a radial direction, this load will be a significant distance from the stepper flange, so the stepper shaft will have a high bending load that'll be changing directions (as the stepper rotates) which causes fatigue breaking of the shaft
sharp musk
fallen nymph
Belts will be pulling on these shafts in a radial direction, this load will be a...
so fix it at the top as well
with a beating
*bearing
fallen nymph
sharp musk
*bearing
Remember that you need to align this bearing to not cause binding and extra radial load